Jev Robot Control — xArm7 Simulation
Self-hostTerminalCompare bounded robot intent and movement choices in a shared apple-to-plate simulation.
by admin · listed 5 days ago
⚡ What System1 does here
About
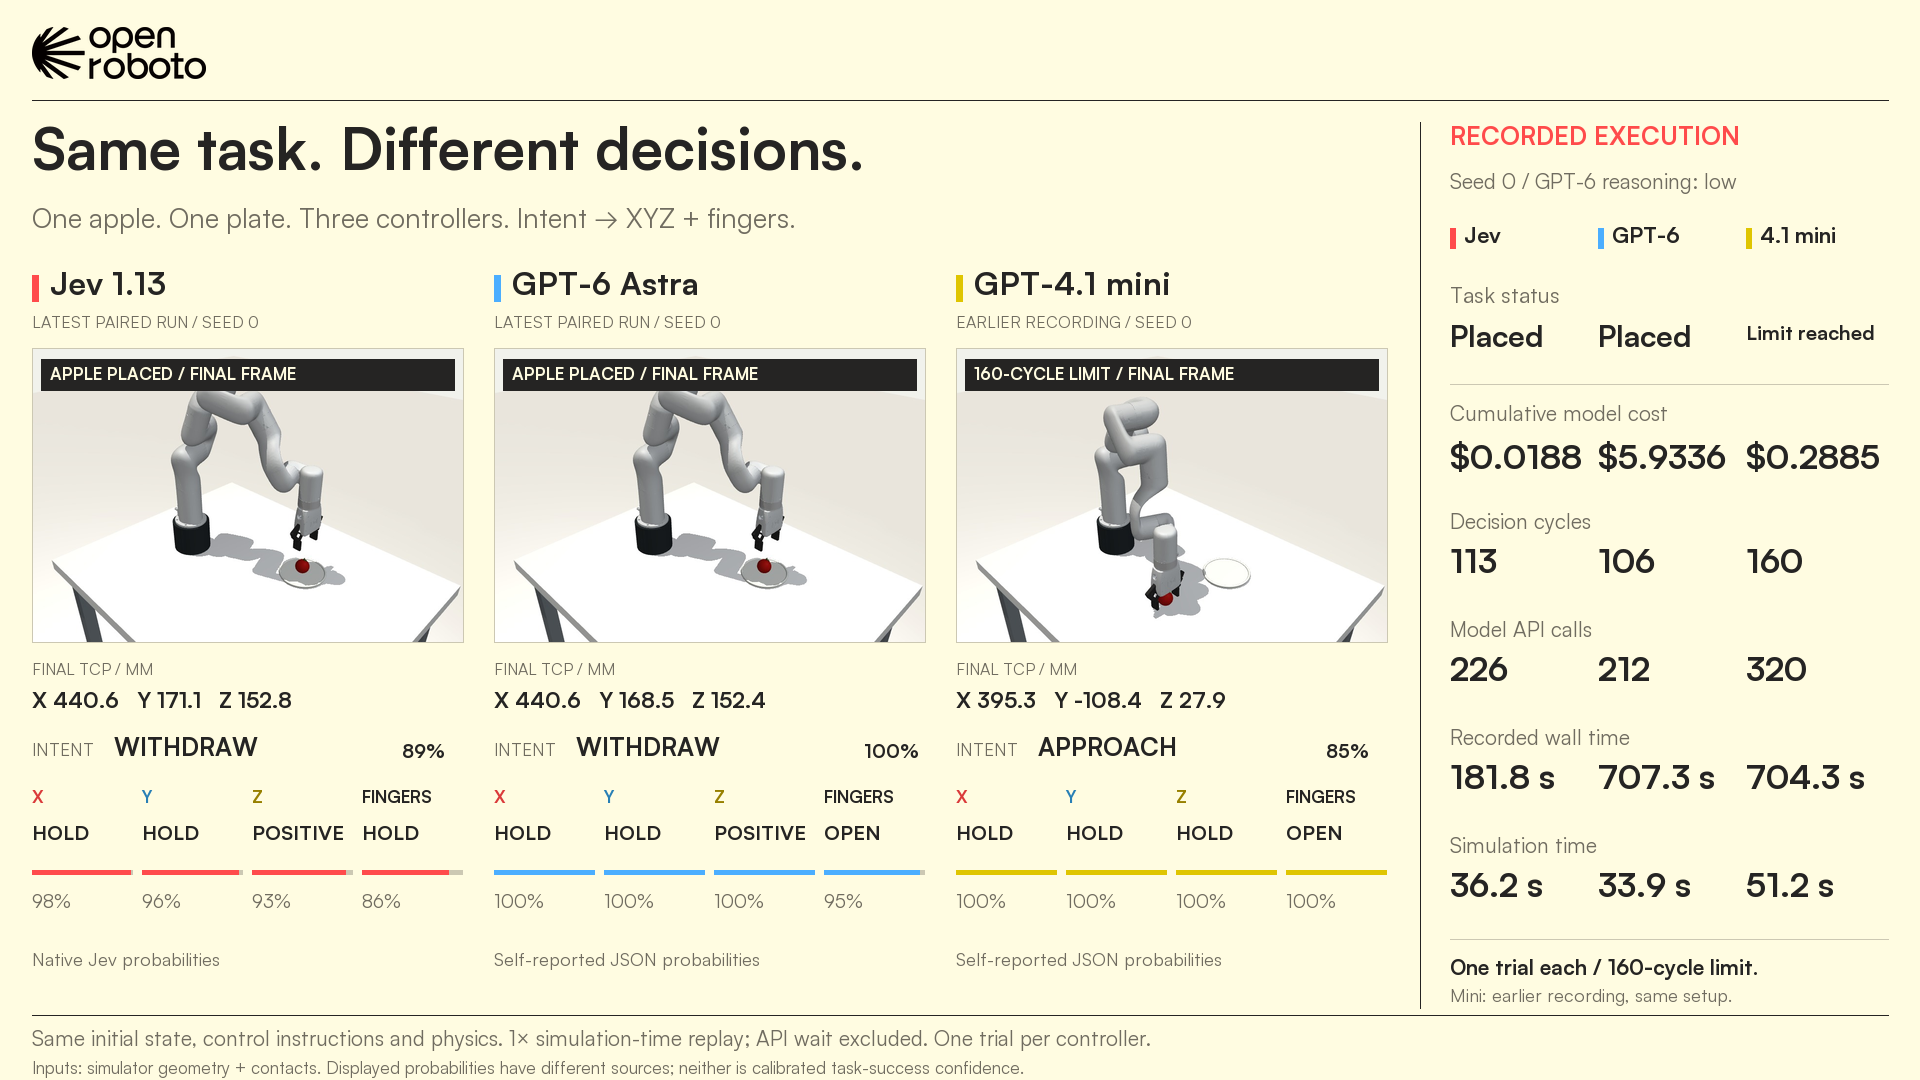
A MuJoCo xArm7 experiment comparing Jev, GPT-6 Astra and GPT-4.1 mini on placing an apple in a plate. The repository publishes responses, trajectories, an offline verifier and a synchronized three-column replay. Existing recordings can be replayed without an API key. Evidence and limits: Each model has one seed-0 trial. The three-panel video combines recordings from different runs and aligns simulation time, excluding API waits. Probability bars are not comparable task-success estimates. Existing replays need no key; fresh trials need paid OpenRouter access. No physical robot was validated. This review checked public documentation, code and media; it did not rerun simulations or test physical hardware. Original project images and demonstrations (with attribution):
Sources: https://github.com/openroboto-ai/jev-robot-control/blob/main/README.md https://github.com/openroboto-ai/jev-robot-control/blob/main/docs/RESULTS.md https://github.com/openroboto-ai/jev-robot-control/blob/main/incremental_policy.py https://github.com/openroboto-ai/jev-robot-control/blob/main/LICENSE