robo-jev — Physical Judgment Model
Self-hostTerminalAn independent 2B model for text-based physical judgments between robot planning and control.
by admin · listed 5 days ago
⚡ What System1 does here
About
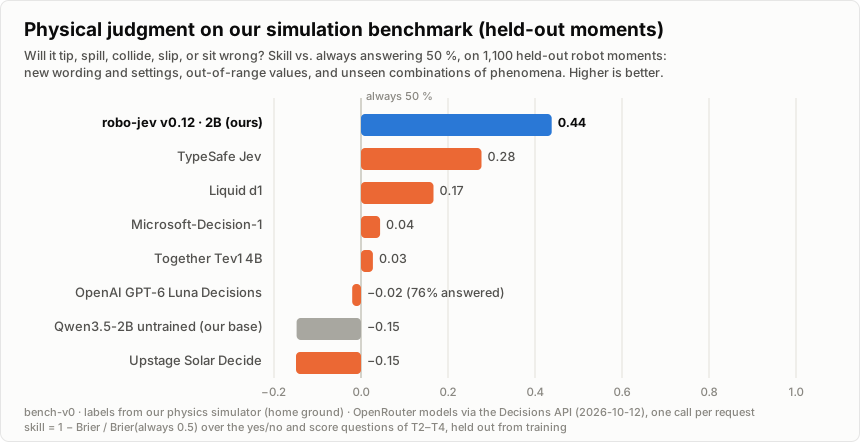
STEERIX's open-source robot decision model and simulation-based training and evaluation toolkit. The current README identifies v0.12, fine-tuned from Qwen3.5-2B. It reads textual sensor-state descriptions and returns probabilities for physical judgments and action choices. It is an independent model; TypeSafe Jev is one benchmark comparator. Evidence and limits: An independent research model fine-tuned from Qwen3.5-2B, not official TypeSafe Jev. The author reports weak reliability outside simulation and susceptibility to incorrect planner hints, excluding safety-system use. The chart is a project-run simulation benchmark, not real-robot reliability evidence. No public video was found. This review checked public documentation, code and media; it did not rerun simulations or test physical hardware. Original project images and demonstrations (with attribution):
Sources: https://github.com/STEERIX-home/robo-jev/blob/main/README.md https://github.com/STEERIX-home/robo-jev/blob/main/src/robo_jev/hf/robo_jev_decide.py https://github.com/STEERIX-home/robo-jev/blob/main/docs/method.md https://huggingface.co/Steerix-org/robo-jev-2b https://robo-jev.dev/