Jev Drone
Self-hostTerminalChoose a detour, climb, brake or target reacquisition while code handles flight control.
by admin · listed 7 days ago
⚡ What System1 does here
About
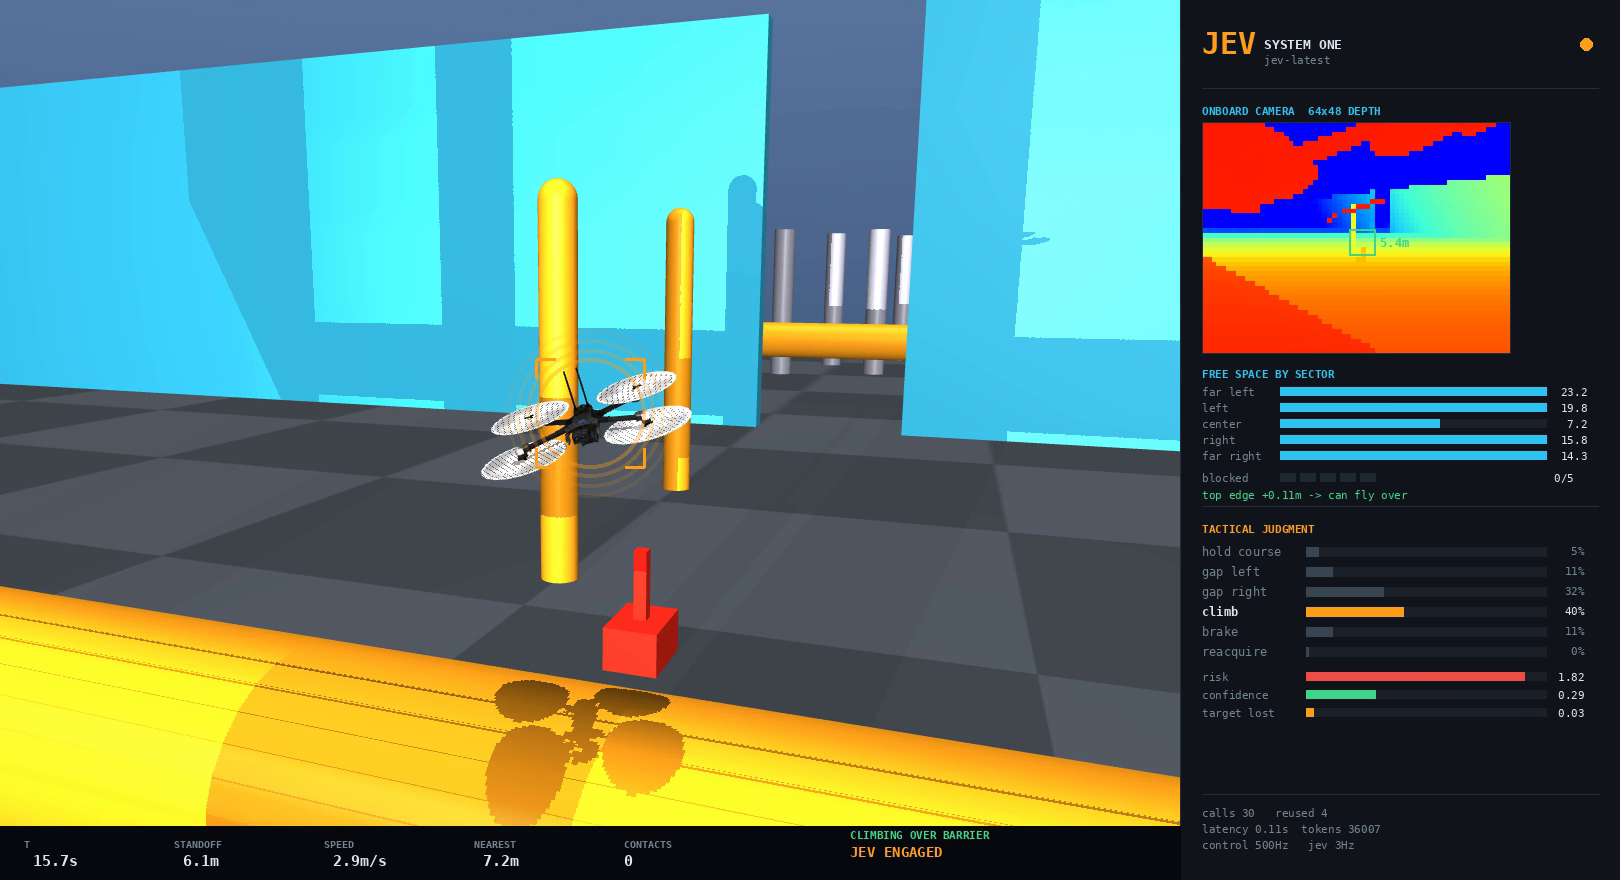
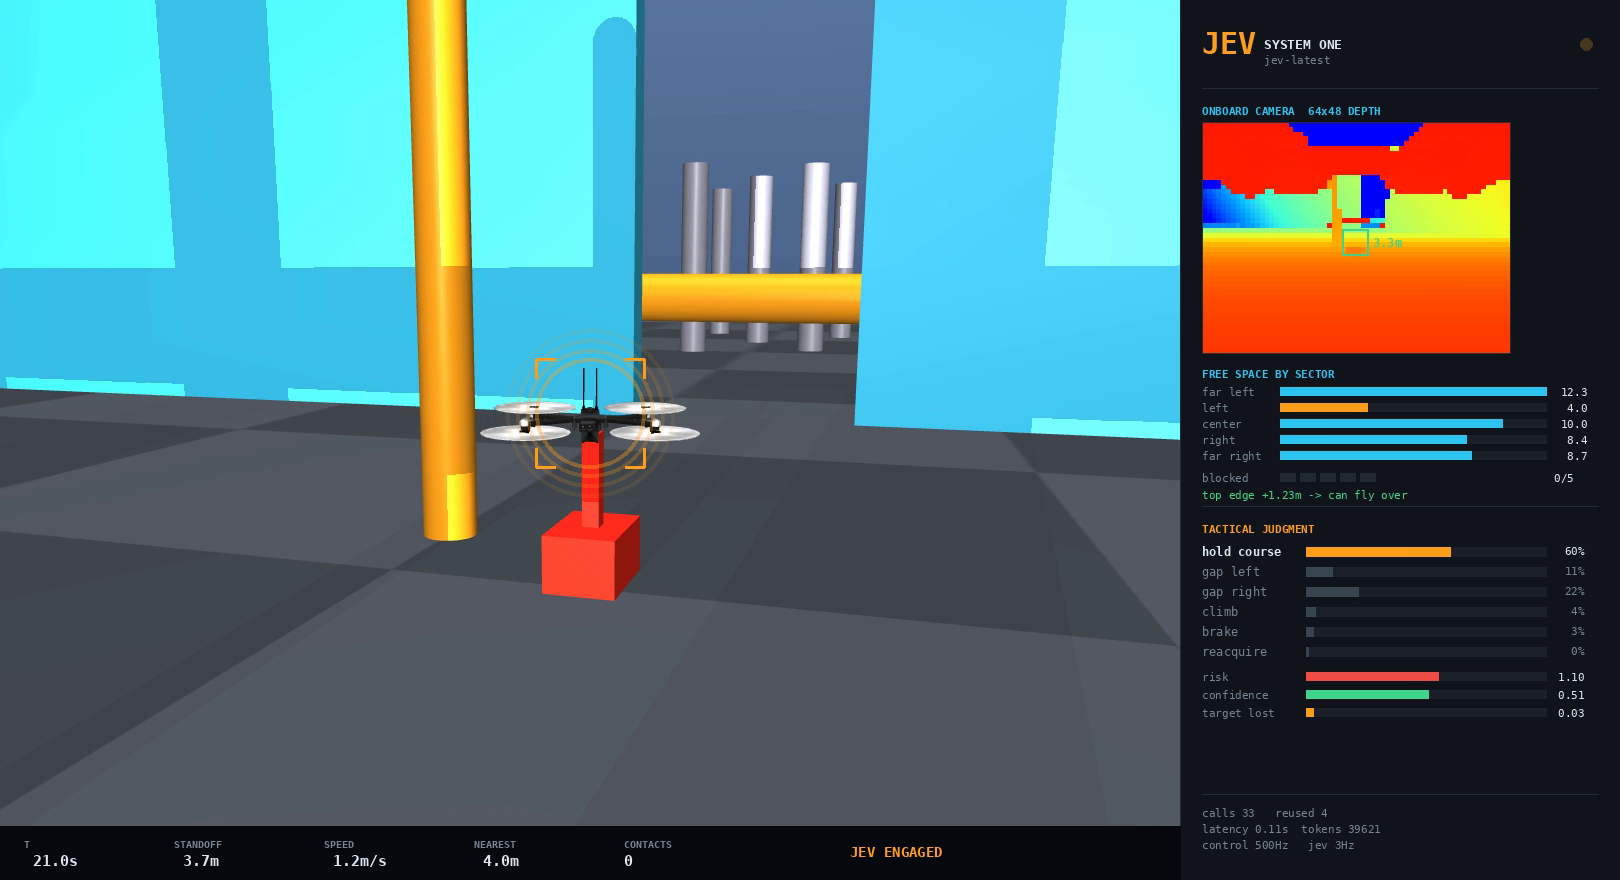
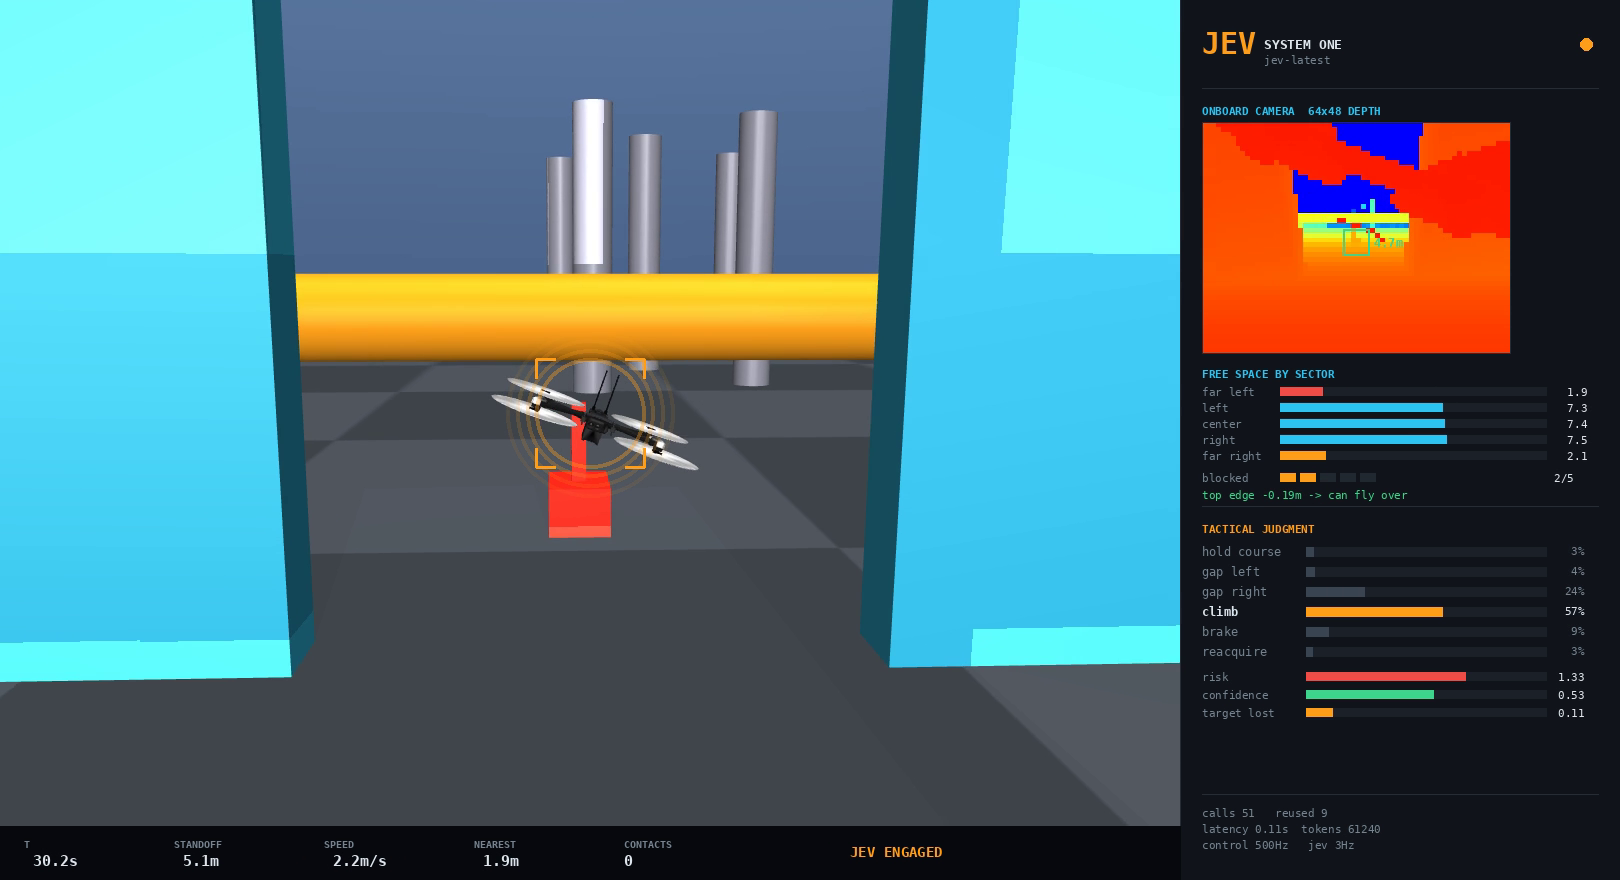
A MuJoCo research demo in which a simulated Skydio X2 follows a ground rover through five obstacle types. It includes flight-control and perception code, an experiment write-up, a course recording and screenshots, plus an incomplete tunnel experiment. Evidence and limits: All evidence is simulated; the model does not consume images. The highlighted success is a single run, and an earlier multi-seed comparison showed no advantage. Different climb options also confound the baseline comparison. The tunnel experiment remains incomplete. Tactical calls are separate from flight control; this does not establish real-drone reliability. This review checked public documentation, code and media; it did not rerun simulations or test physical hardware. Original project images and demonstrations (with attribution):
Sources: https://github.com/RomanSlack/jev-drone/blob/main/README.md https://github.com/RomanSlack/jev-drone/blob/main/tactics.py https://github.com/RomanSlack/jev-drone/blob/main/site/app/page.tsx https://github.com/RomanSlack/jev-drone/blob/main/site/lib.ts https://jev-drone.vercel.app/