Inner Monologue — Feedback-Driven Robot Planning
Demo onlyUse fresh execution, scene and human feedback to revise a robot plan.
by admin · listed 5 days ago
⚡ What System1 does here
About
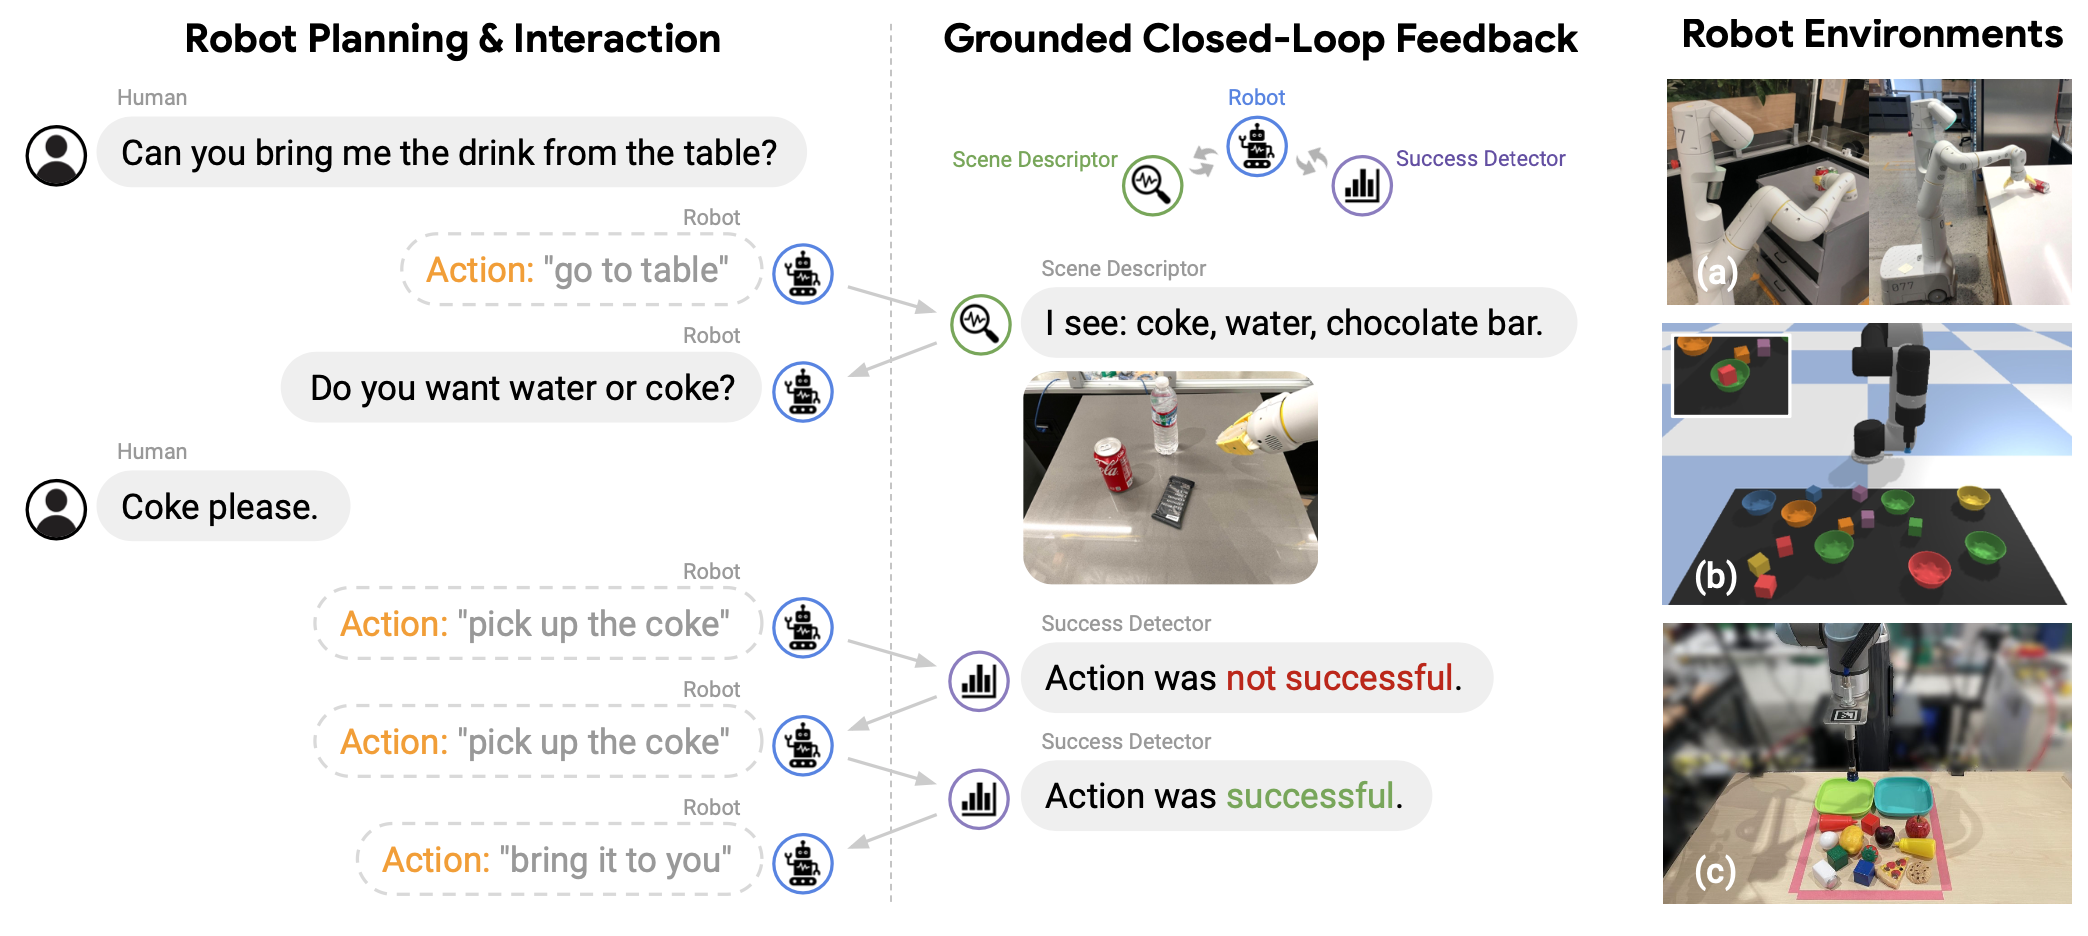
A research method for feedback-driven robot planning: after an action fails, the planner can revise the next steps using updated observations. Evaluations cover simulated tabletop tasks, real tabletop manipulation and a mobile robot in a kitchen. Evidence and limits: Results depend on feedback quality and available skills. Some recovery demonstrations deliberately induce failures through human intervention. These research results do not establish reliability across arbitrary household tasks, robots or production settings. We did not run the project. Original project images and demonstrations (with attribution):
Sources: https://innermonologue.github.io/ https://arxiv.org/abs/2207.05608 https://youtu.be/0sJjdxn5kcI